Recently published:
Ji, A., Ma, Z., Yang, H., Khattak, A. J. and Levinson, D. (2026) Learning from common knowledge: A multi-agent cooperative ramp merging framework for decentralized autonomous vehicles. Transportation Research Part E: Logistics and Transportation Review, 105275. Available online 12 October 2026 (in press, corrected proof). [doi]
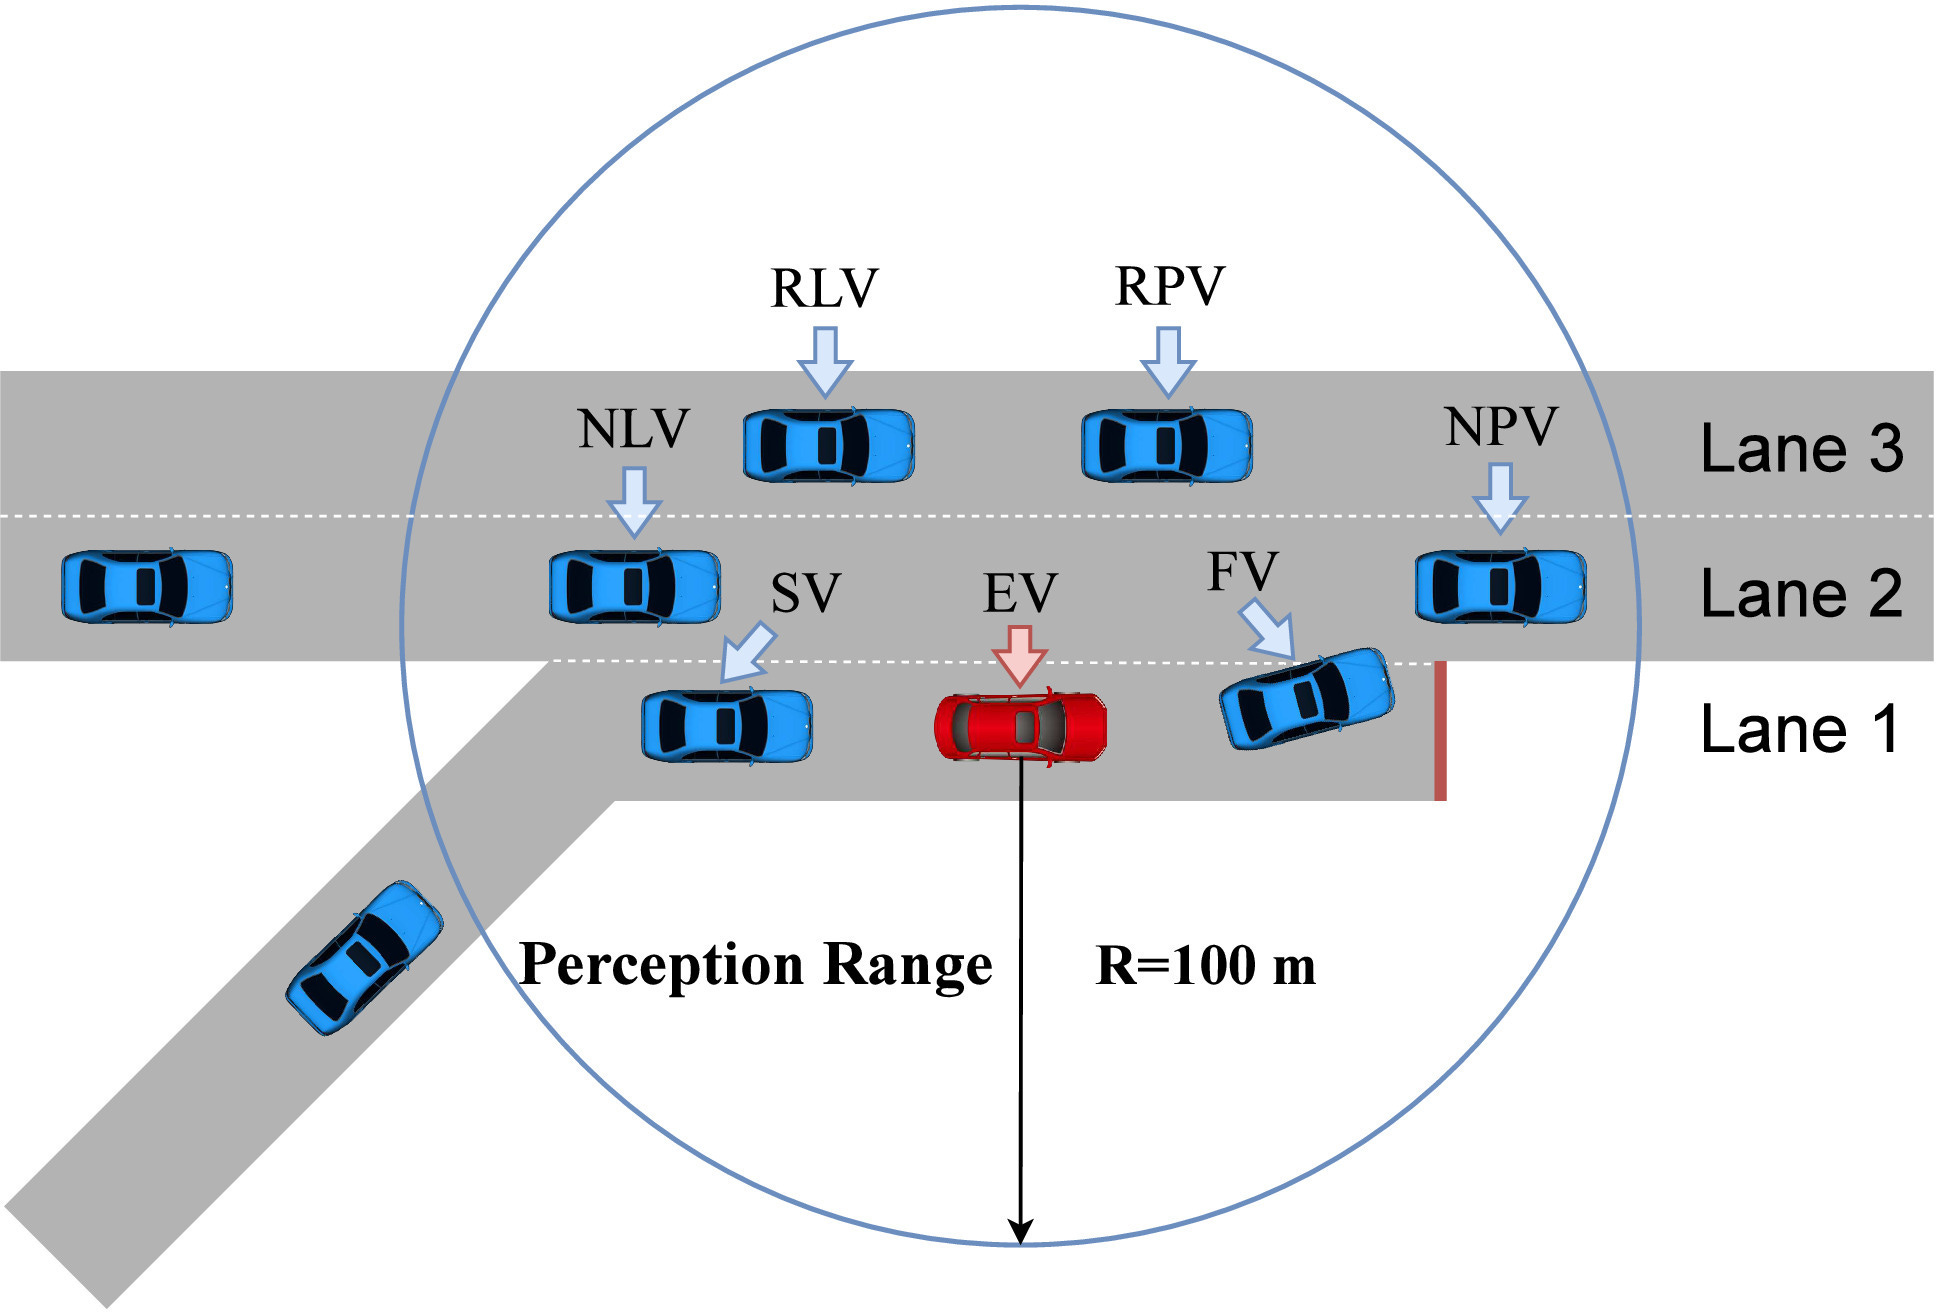
This paper proposes a multi-agent reinforcement learning (MARL) framework that combines an offline shared pool of information (SPI) with hypernetworks to enable cooperative on-ramp merging among high-level autonomous vehicles (AVs), leveraging common knowledge for spontaneous cooperation. First, we discuss the construction method of the common knowledge base-SPI from two approaches: model- and data-driven methods. Then, we design an on-board fine-tuning algorithm that enables each agent to refine its policy from local observations without any communication protocols. Based on the above advances, we develop a hybrid SPI-based on-ramp merging strategy driven by the physical model and human driving data. Finally, the proposed framework is evaluated in simulated peak- and off-peak traffic scenarios calibrated by the Zen trajectory dataset. The results demonstrate improved traffic efficiency outcomes and fewer collision occurrences than several baselines under the evaluated conditions. The findings reveal possible research directions for future work and provide insights for the application of the decentralized-training-decentralized-execution framework in autonomous driving.
Keywords:
Autonomous vehicles; Multi-agent reinforcement learning; Ramp merging; Shared information pool